Process Overview
This deployment is a box pick-and-place automation solution using a Box Picker Gripper.
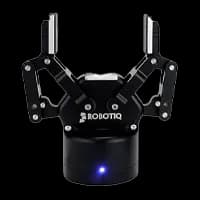
As the name suggests, the Box Picker Gripper is designed to pick a wide range of objects. In this solution, it enables stable picking even when plastic boxes are open-top (without lids), improving handling reliability in box transfer operations.
Components
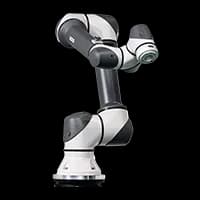
| Robot | Robot + gripper Box Picker Gripper Size can be customized to match the workpiece requirements |
|---|---|
| Peripherals | TVM1200 6-axis articulated robot 6 torque sensors Payload: 15 kg Repeatability: ±0.05 mm Reach: 1,432 mm Robot weight: 125 kg |
Workflow
| STEP 1. | The robot moves down to the pick position |
|---|---|
| STEP 2. | The gripper picks the box |
| STEP 3. | The robot moves up |
| STEP 4. | The robot moves to the target position |
| STEP 5. | The robot moves down |
| STEP 6. | The gripper places the box. |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Recommended Use Cases
Automated nut loading into the machine tool—plus complete teaching support!
Process Overview Philliper had been handling the process of inserting nuts into the machine tool manually. Due to the repetitive nature of the work and insufficient precision, this led to reduced productivity and quality issues. To resolve this, they implemented an automation solution using four Hyundai robots and two Doosan robots. Project Background and Objectives Background Philliper was experiencing work inefficiency and inconsistent quality in the existing nut-loading operation due to a manual process. Key issues Speed loss and quality variation occurring during manual operations Increased operator fatigue and reduced productivity Operator burden caused by repetitive tasks in the nut insertion process Objectives Improve production efficiency by automating repetitive tasks through robot deployment Secure consistent quality and reduce defect rates through accurate insertion Improve the work environment by reducing operator fatigue and strengthening safety

Automated Electric Vehicle Console Assembly with EPSON SCARA Robots! 🦾
Process Overview Bigwave Robotics (Marosol) established an automated assembly line for console parts for Kia Motors' newly launched SUV-type electric vehicle. The existing console assembly line is a large-scale assembly line, requiring an average of 40-60 workers to assemble manually. The lack of automation experience presented challenges in securing space and recruiting assembly workers. Frequent staff turnover and resulting skill level issues hindered productivity. To address this, the company replaced some workers with robots, addressing the labor shortage and consistently ensuring productivity by adapting to the changing workforce. Warranty Period 1 Year Performance Year 2024 Project Duration 4 Months Project Background and Objectives Building a multi-product automated production line and reducing labor costs through robotic automation Preventing mis-assembly and mis-assembly using a lot-of-lot system and ensuring traceability Remote control and integrated management using SOLlink
YASKAWA Industrial Robot Hanger-Box Palletizing Automation
Process Overview This deployment uses a YASKAWA GP180 to palletize boxes of hanger products weighing over 20 kg onto pallets. By replacing manual handling in heavy-payload work, it helps prevent musculoskeletal disorders and enables faster, more consistent palletizing performance. Note: Cost may vary depending on the installation environment, robot brand, and payload requirements.
Process Overview
This deployment is a box pick-and-place automation solution using a Box Picker Gripper.
As the name suggests, the Box Picker Gripper is designed to pick a wide range of objects. In this solution, it enables stable picking even when plastic boxes are open-top (without lids), improving handling reliability in box transfer operations.
Components
| Robot | Robot + gripper Box Picker Gripper Size can be customized to match the workpiece requirements |
|---|---|
| Peripherals | TVM1200 6-axis articulated robot 6 torque sensors Payload: 15 kg Repeatability: ±0.05 mm Reach: 1,432 mm Robot weight: 125 kg |
Workflow
| STEP 1. | The robot moves down to the pick position |
|---|---|
| STEP 2. | The gripper picks the box |
| STEP 3. | The robot moves up |
| STEP 4. | The robot moves to the target position |
| STEP 5. | The robot moves down |
| STEP 6. | The gripper places the box. |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Related Use Cases
Automated nut loading into the machine tool—plus complete teaching support!