Process Overview
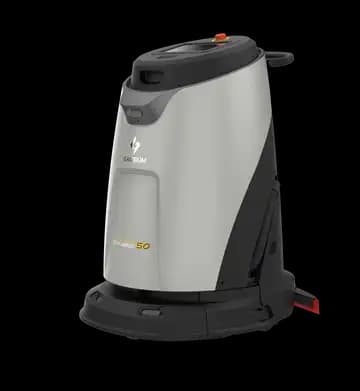
This case study demonstrates an inline logistics solution that utilizes the Yujin Robot GoCart180 and an upper conveyor module to automatically transport plastic injection products from the injection molding machine to the shipping facility.
By developing a conveyor module tailored to the customer's production line, we automated product loading and unloading, achieving complete automation throughout the entire inline transport process without operator intervention.
Warranty Period
- 1 Year
Performance Year
- 2023
Project Duration
- Need for consultation
Project Background and Objectives
- Injection molding manufacturing in-line labor shortage
- Factory operations are disrupted due to difficulties securing workers
- Workers avoid work due to the risk of musculoskeletal disorders and industrial accidents
Components
| Robot | Two Yujin Robot GoCart180 ; Payload: 180kg ; ISO 13482 PLd safety standard certified ; Operating speed: up to 1.0m/s |
|---|---|
| Peripherals | Upper electric conveyor module ; Order picking cart ; Middleware |
Workflow
| STEP 1. | After the injection molding machine injects the food container, it is discharged onto the conveyor |
|---|---|
| STEP 2. | When the injection product reaches a certain amount, the AMR is automatically called |
| STEP 3. | The injection product is automatically loaded from the injection molding machine conveyor to the upper conveyor of the AMR |
| STEP 4. | The AMR moves the injection product to the shipping space |
| STEP 5. | The injection product is automatically unloaded from the AMR conveyor to the shipping conveyor |
| STEP 6. | The worker packages and ships the product. |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Recommended Use Cases

AMR logistics robots introduced to manufacturing factory ✨ Logistics automation that quickly resolves even 1 ton of waste drbris (2 KUKA KMP 1500P logistics robots)
Process Overview This case study demonstrates the installation of a KUKA KMP 1500P logistics robot at Bigwave Robotics (Marosol) to transport rollers and scrap debris within the space manufacturing facility. The KMP 1500P autonomously handles up to 1 ton of scrap debris over a 1.2 km distance and automatically transports heavy-duty roller modules weighing up to 1 ton. Furthermore, sensors embedded in the KMP 1500P enabled the development of an unmanned system capable of safely transporting heavy-duty materials. Project Background and Purpose Automated unmanned transport using autonomous robots Robots perform simple, repetitive tasks Safe operation of heavy-duty products using various sensors Remote control and monitoring using SOLlink

An order picking system solution for logistics warehouses utilizing AMRs
Process Overview This case study demonstrates an order picking system that optimizes the operation of ten Eugene Gocart 180s using Marosol's remote control system, SOLlink. With the self-developed SOLlink, multiple AMRs are clustered and controlled to maximize logistics system efficiency. The order picking system, integrated with WMS, allows for flexible handling during peak periods without the need for additional workers. Warranty Period 1 Year Performance Year 2023 Project Duration Need for consultation Project Background and Objectives Improved workforce supply and employment stability through the introduction of logistics robots Introducing robots for high-intensity, repetitive tasks reduces the risk of musculoskeletal disorders and industrial accidents among workers Integrating WMS and order picking systems increases work efficiency and reduces error rates

A House Built by Robots?! Space Factory Automates Modular Housing Window Assembly! 🛠️🏠
Project Overview This case marks Korea's first automated solution for modular housing window assembly, combining a KUKA industrial robot, a custom-designed robotic gripper, and a High Payload Track Motion system. Space Factory introduced this automation system to reduce construction costs and ensure consistent quality in modular housing production. Background & Objective Traditionally, skilled workers manually assembled window frames on-site, which was time-consuming and labor-intensive. Meeting diverse client requirements also demanded a large workforce. In addition, the wide and complex work environment made real-time monitoring and process control difficult. The goal of this project was to automate the window assembly process to significantly reduce work time, establish a standardized production system for consistent quality, and enhance process management through real-time production monitoring.
Process Overview
This case study demonstrates an inline logistics solution that utilizes the Yujin Robot GoCart180 and an upper conveyor module to automatically transport plastic injection products from the injection molding machine to the shipping facility.
By developing a conveyor module tailored to the customer's production line, we automated product loading and unloading, achieving complete automation throughout the entire inline transport process without operator intervention.
Warranty Period
- 1 Year
Performance Year
- 2023
Project Duration
- Need for consultation
Project Background and Objectives
- Injection molding manufacturing in-line labor shortage
- Factory operations are disrupted due to difficulties securing workers
- Workers avoid work due to the risk of musculoskeletal disorders and industrial accidents
Components
| Robot | Two Yujin Robot GoCart180 ; Payload: 180kg ; ISO 13482 PLd safety standard certified ; Operating speed: up to 1.0m/s |
|---|---|
| Peripherals | Upper electric conveyor module ; Order picking cart ; Middleware |
Workflow
| STEP 1. | After the injection molding machine injects the food container, it is discharged onto the conveyor |
|---|---|
| STEP 2. | When the injection product reaches a certain amount, the AMR is automatically called |
| STEP 3. | The injection product is automatically loaded from the injection molding machine conveyor to the upper conveyor of the AMR |
| STEP 4. | The AMR moves the injection product to the shipping space |
| STEP 5. | The injection product is automatically unloaded from the AMR conveyor to the shipping conveyor |
| STEP 6. | The worker packages and ships the product. |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Related Use Cases
AMR logistics robots introduced to manufacturing factory ✨ Logistics automation that quickly resolves even 1 ton of waste drbris (2 KUKA KMP 1500P logistics robots)
An order picking system solution for logistics warehouses utilizing AMRs